
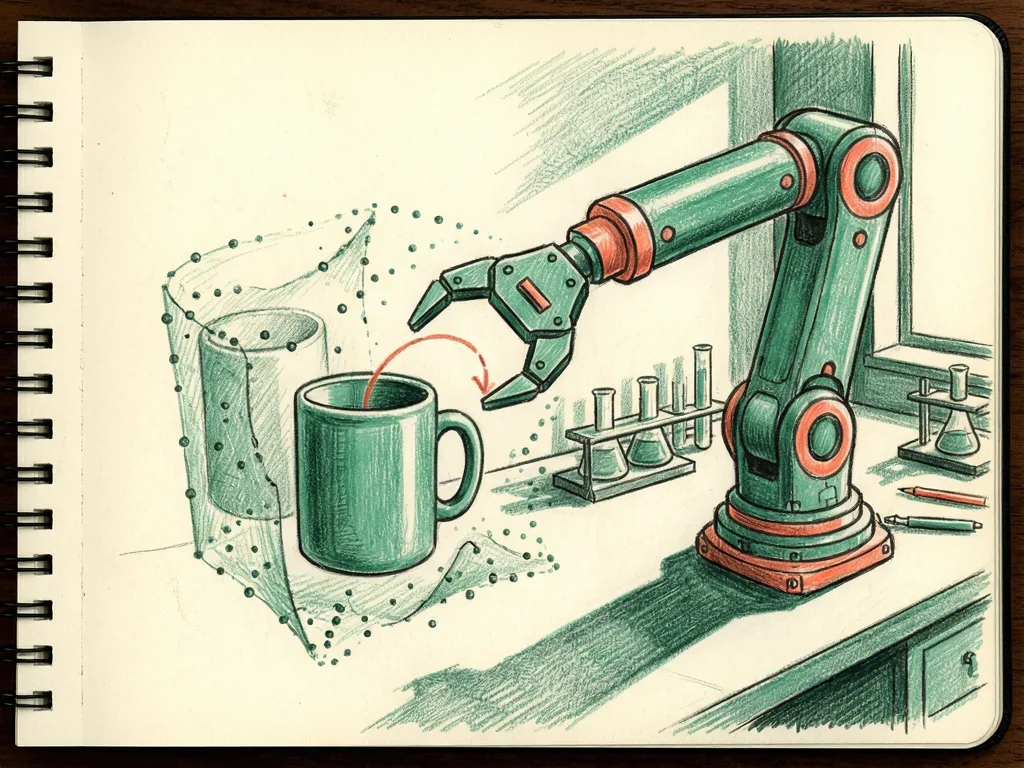
RynnVLA-Latent scales robotic manipulation foundation models by grounding latent actions in three-dimensional space.
RynnLAM creates latent action targets from 30,100 hours of human, robot, and simulation video; RynnVLA-Latent transfers them into real robot control.